Student-built robots.
Designed for competition.
The team behind
the robot.
We are X.PLORE, a community robotics team from Songjiang, Shanghai. Founded in June 2025, we entered FIRST Robotics Competition in 2026.
Students work on mechanical design, software, fabrication and communication to build and operate the robot.
Get to know the team- Founded in Songjiang
- 2025
- Official events in the rookie season
- 3
- Awards across those events
- 4
- Official match record
- 26–12
THE MACHINE
BEHIND THE SEASON.
Collect.
From floor intake to shooter.
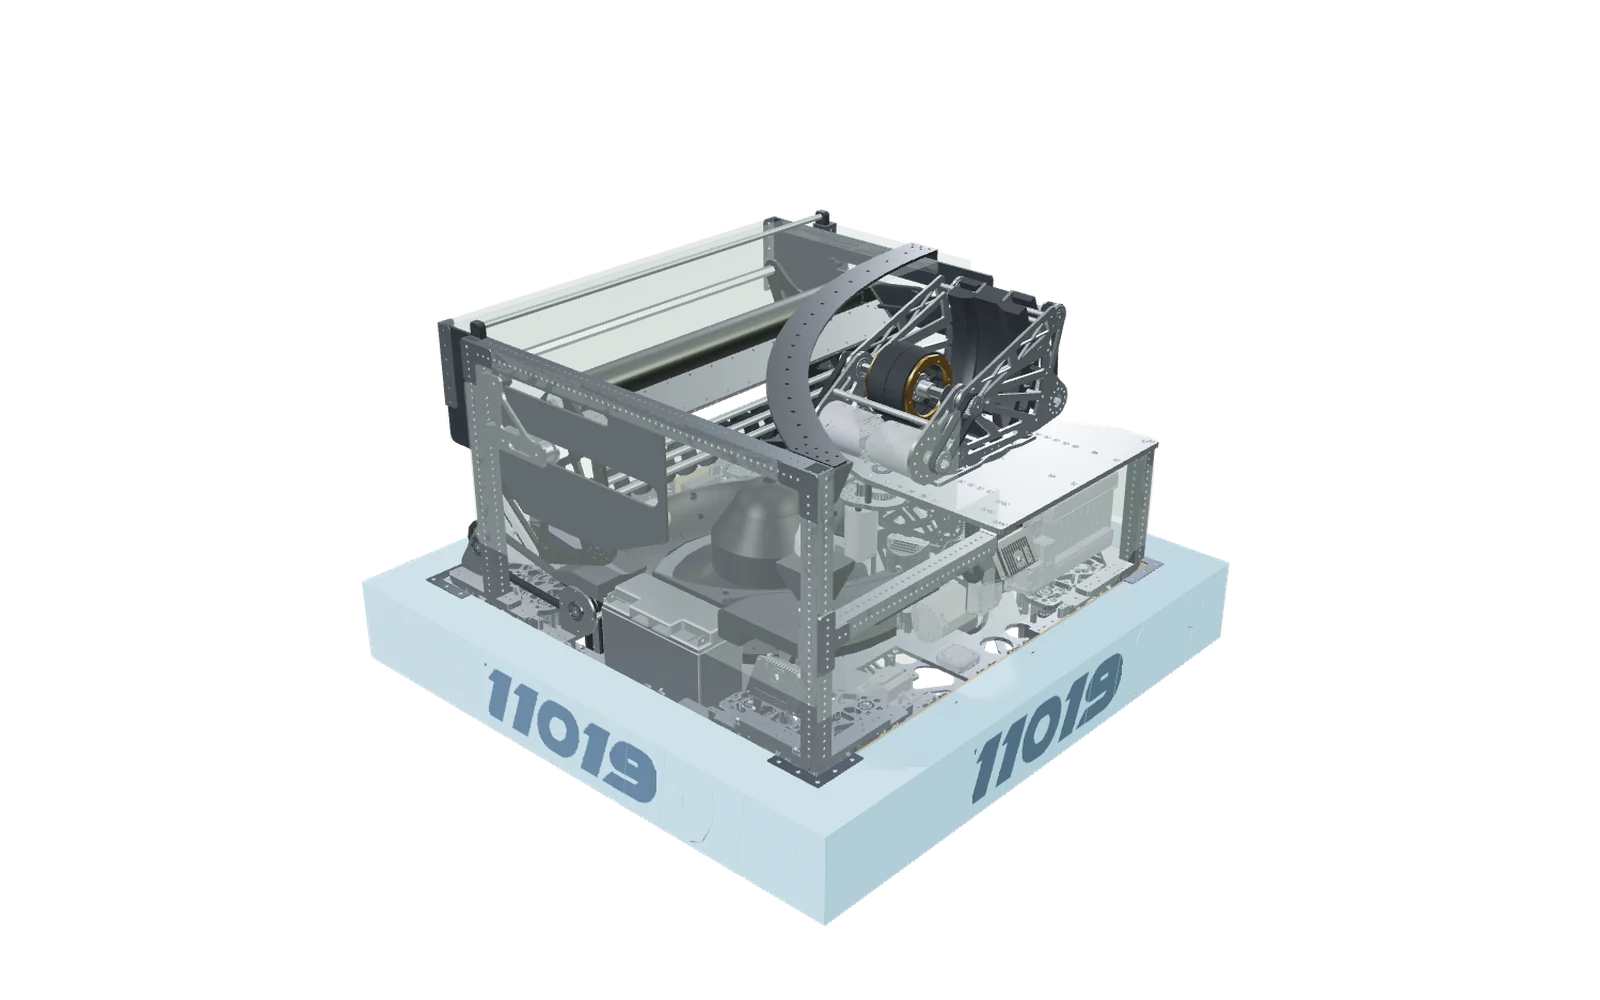
Rollers collect FUEL, the game’s foam balls. The hopper stores them, and the feeder delivers them to the shooter.
Explore the 2026 robot ↗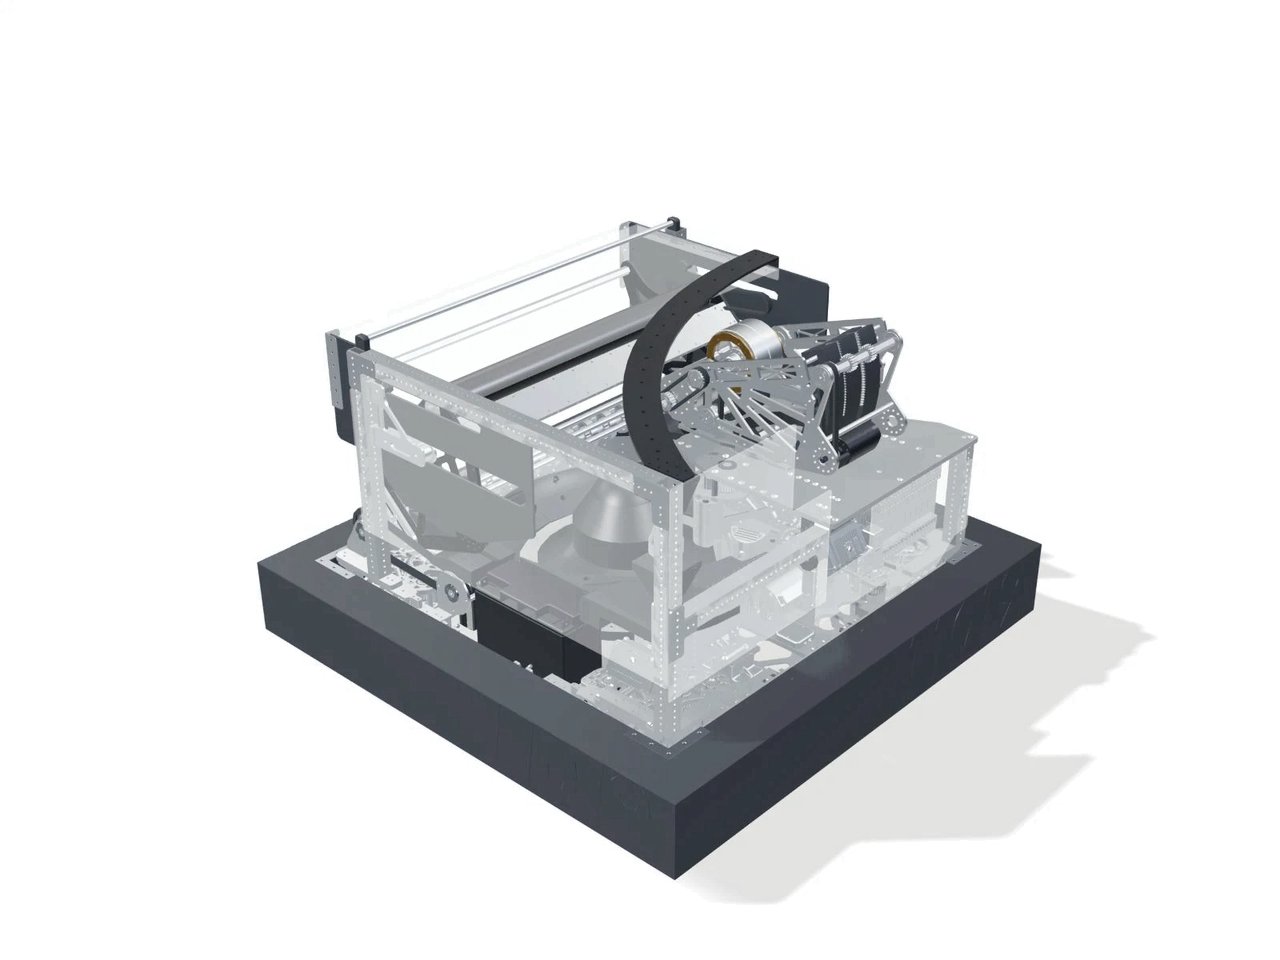
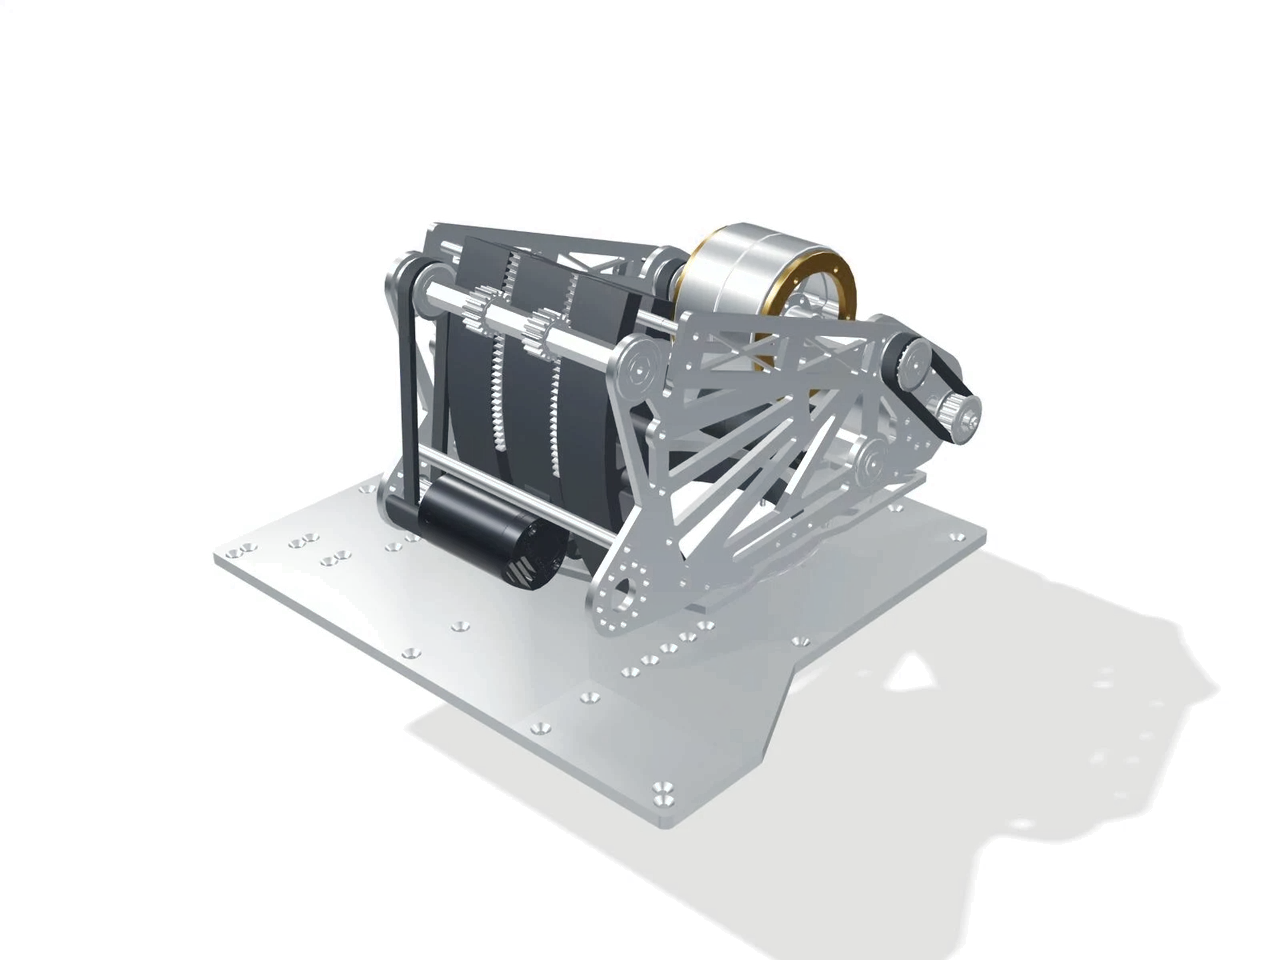
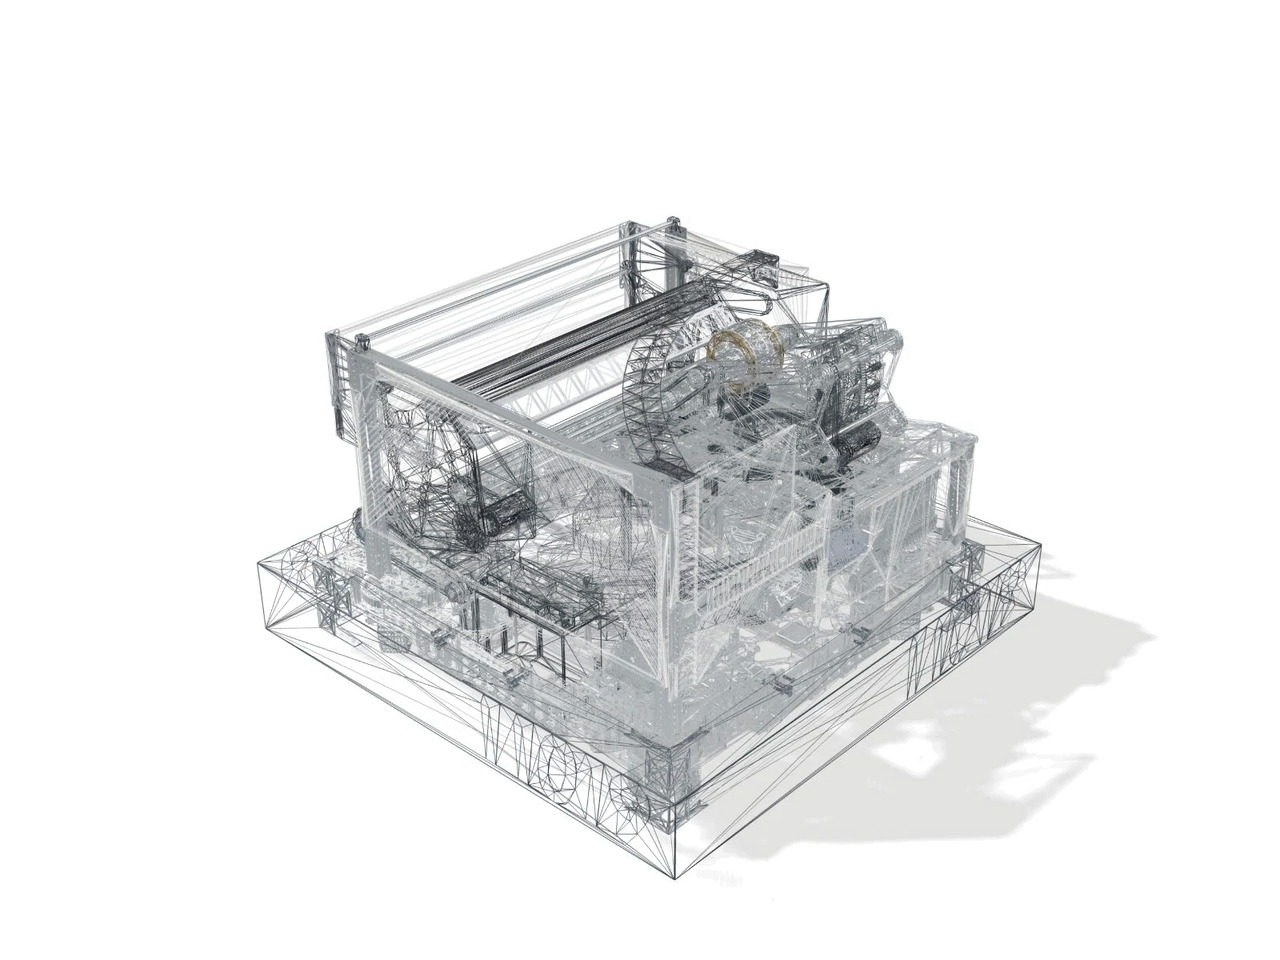
- Intake roller diameter
- 35mm
- Hopper travel
- 260mm
Hawaii Regional
Winners.
Alliance 1. Together with 359 Hawaiian Kids and 9715 Tsinelas’. A regional championship in our first FRC season.
Explore the 2026 season ↗- Shanghai6–5W–LRising All-Star Award
- Honolulu17–0W–LRegional Winners · Judges’ Award
- Houston3–7W–LRookie All Star Award
Three events. Four awards.Official competition records · 2026
Robotics and
shadow puppetry.
Team members visited Songjiang shadow-puppetry practitioner Tang Jiachang to explore how 3D printing and digital tools could support traditional patterns and craft.
Explore community work ↗Everything we learned,
published.
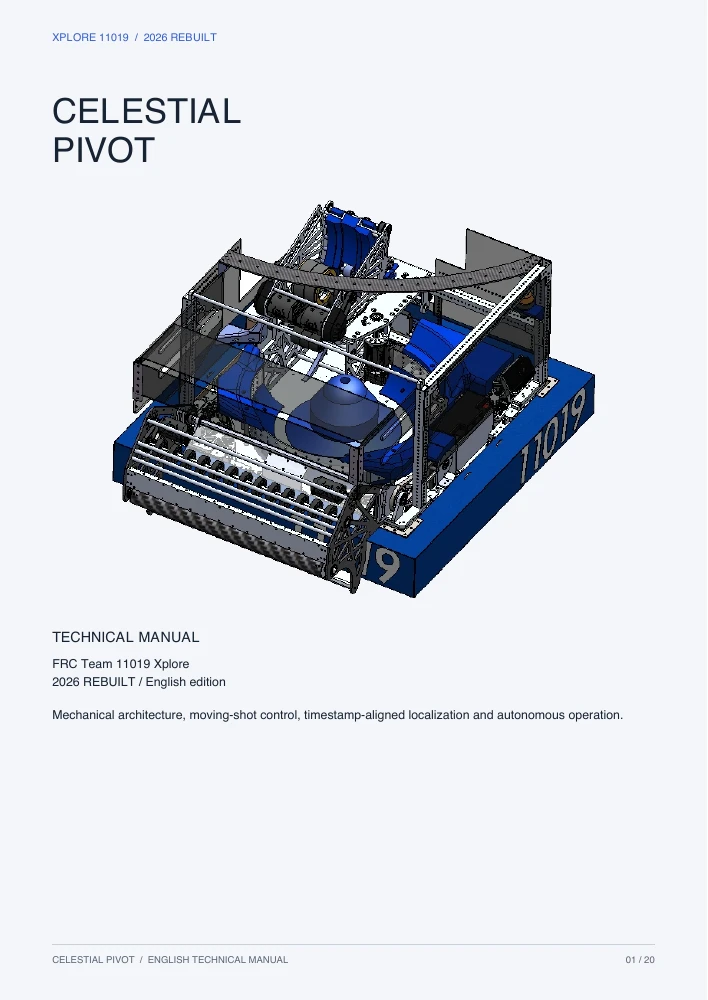
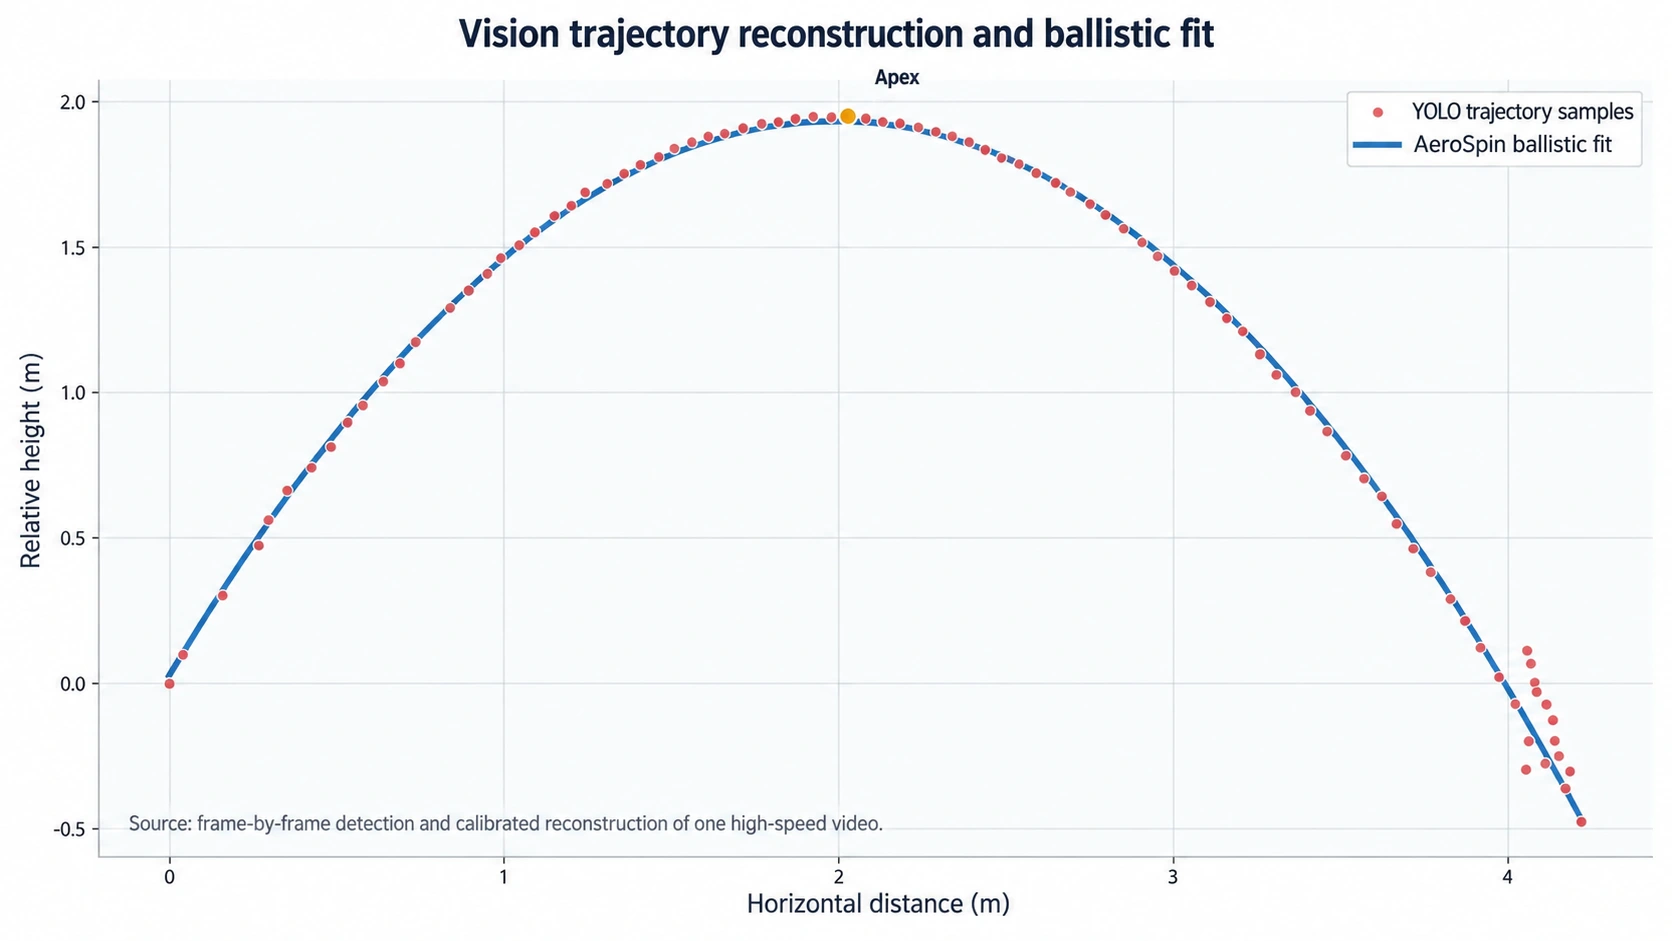
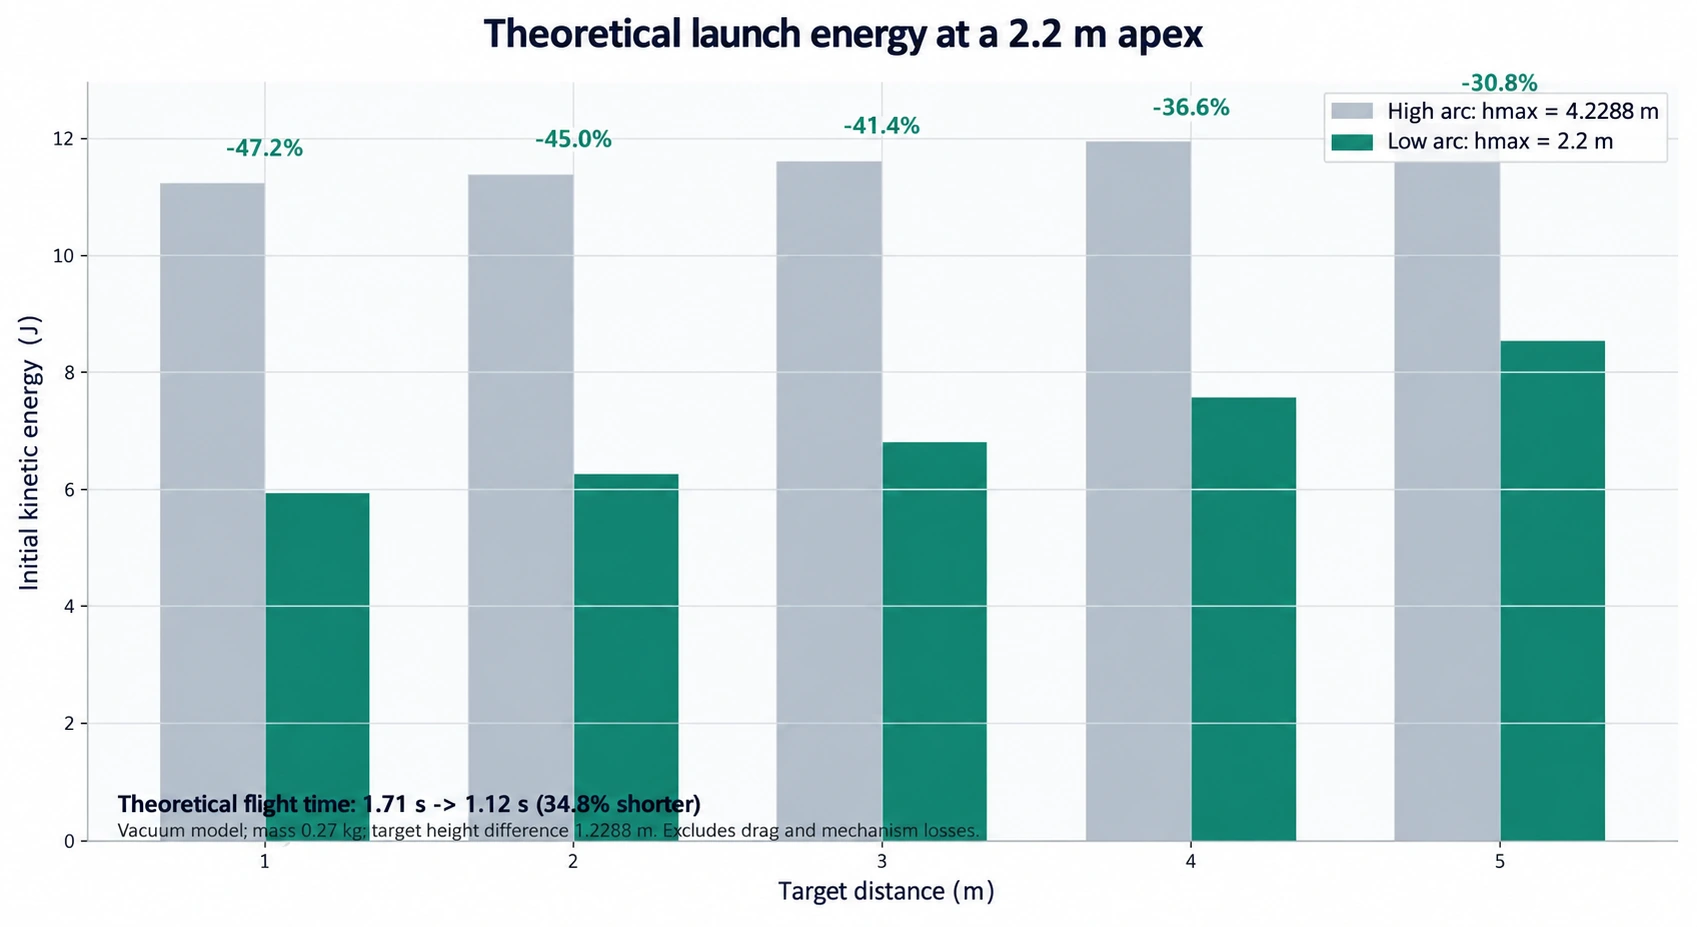
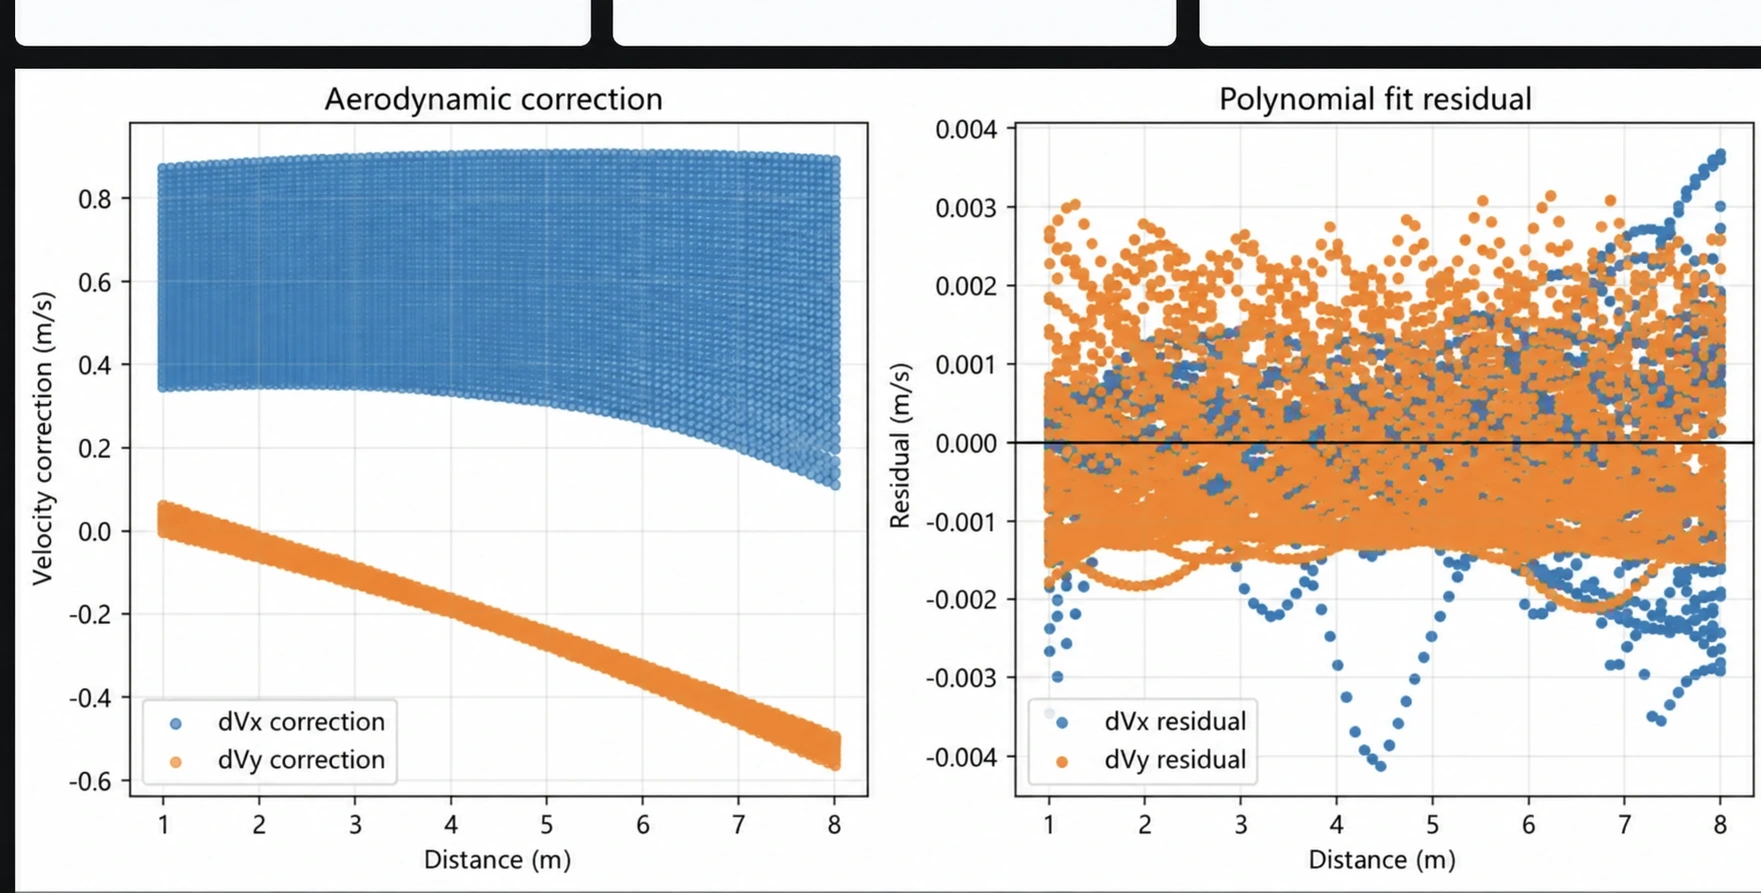
The 2026 robot is documented in the open: design decisions, shot calculation, camera-delay correction and autonomous control, written up in English for other teams, students and judges.
- Pages in the English technical manual
- 20
- Engineering and season notes
- 12
- CAD assemblies to explore in 3D
- 4
- Public repositories on GitHub
- 3