PDF / ENGLISH
↓2026 technical binder
20 pages · 5.5 MB
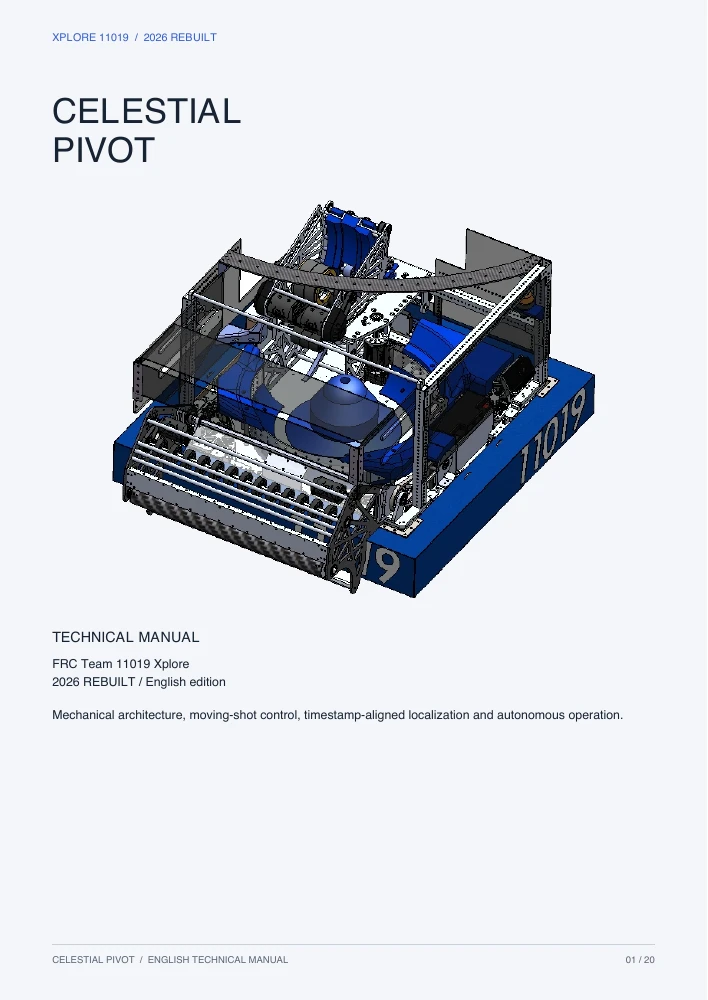
Mechanical design, VISTAeroSpin-5D shot calculation, shooting while moving, camera-delay correction and autonomous control, with diagrams and specifications.
March 2026 manual Join the team ↗
Download the English technical manual and robot images. Browse public software examples.
Read the English manual for design details and specifications. Browse software examples and robot images, or explore the robot in the online 3D viewer.
8 resources shown
20 pages · 5.5 MB
Mechanical design, VISTAeroSpin-5D shot calculation, shooting while moving, camera-delay correction and autonomous control, with diagrams and specifications.
March 2026 manual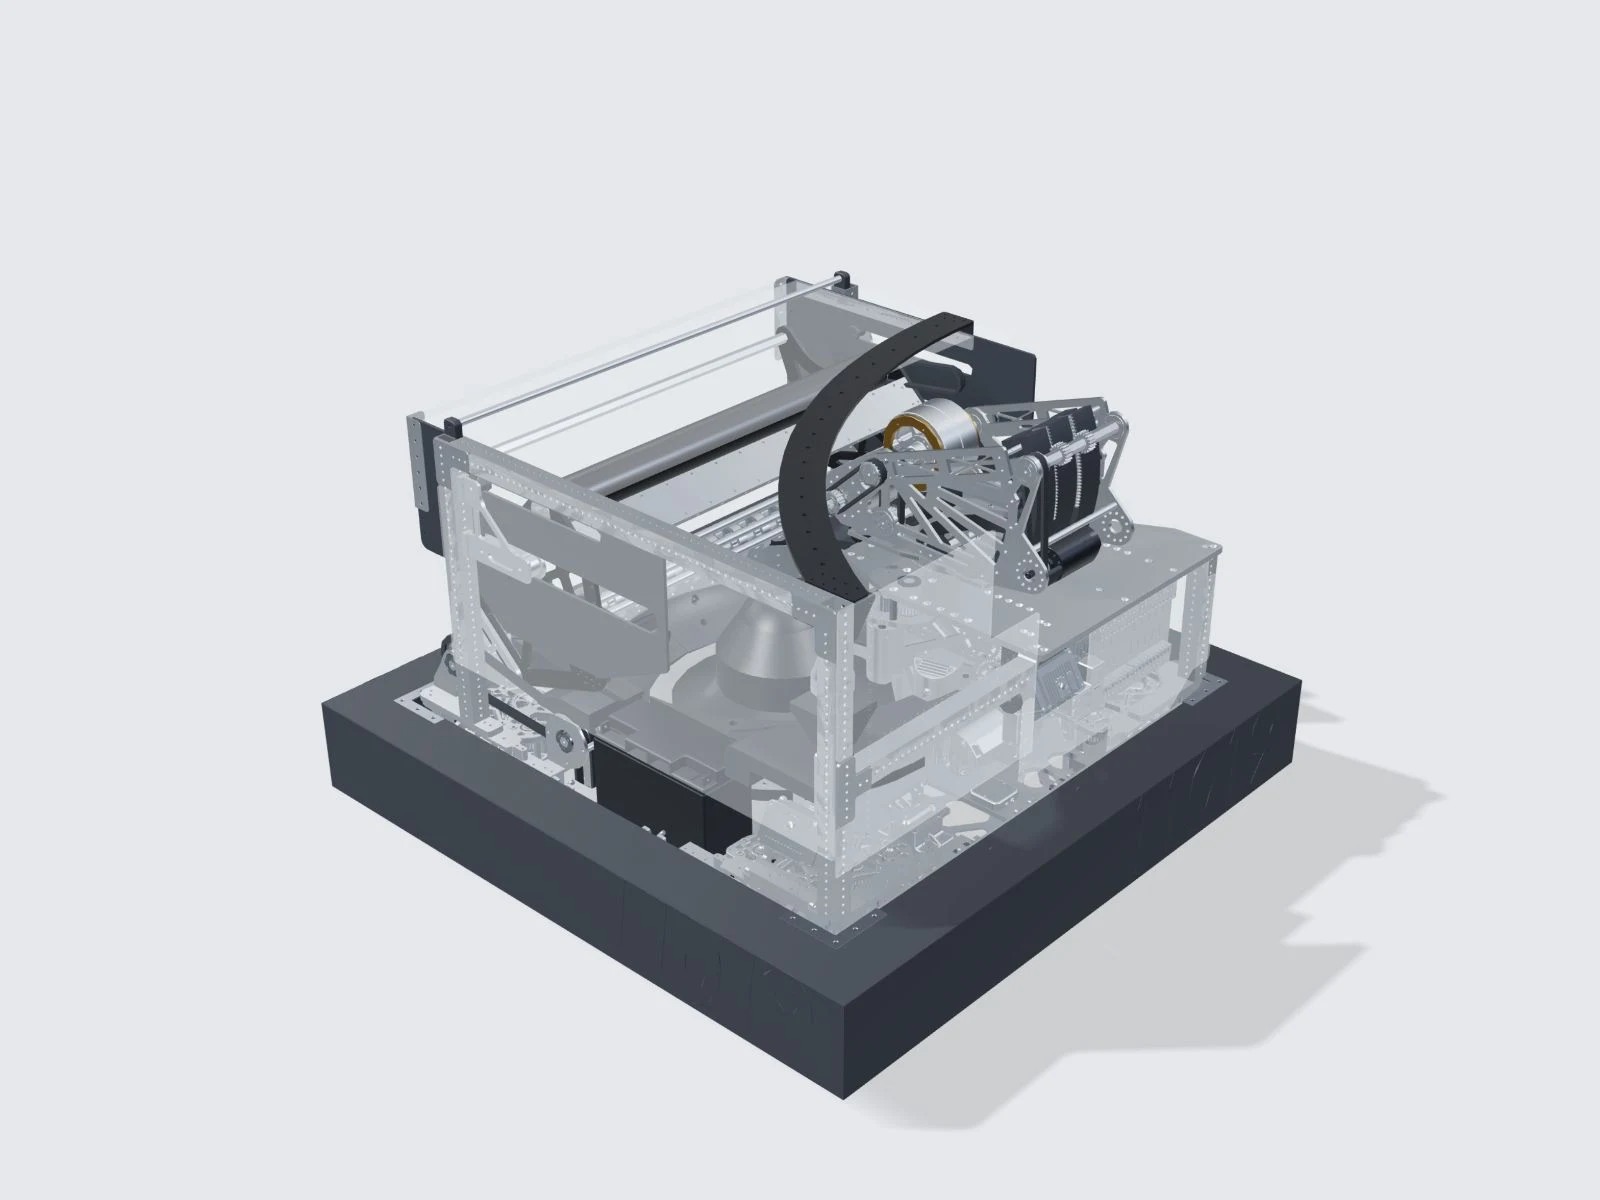
1600 × 1200
A material-rendered view of the complete supplied geometry, suitable for presentations and technical discussion. Display finishes are illustrative.
September CAD-derived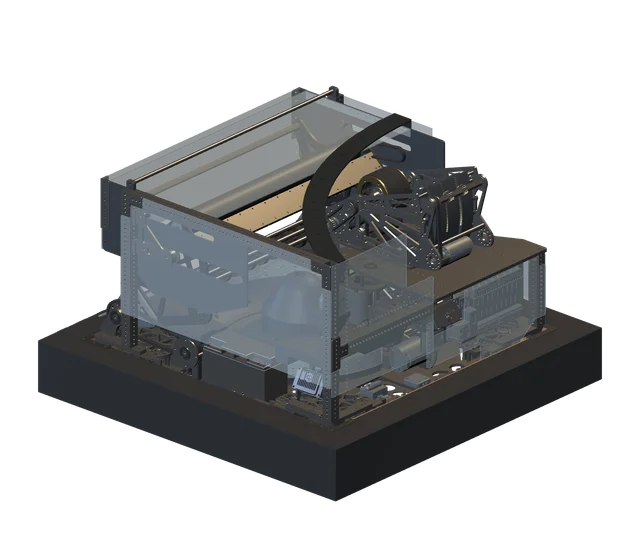
Transparent background
A transparent-background rendering of the supplied assembly for presentation layouts. Retain the original geometry and do not imply that the image is an as-built photograph.
September CAD-derived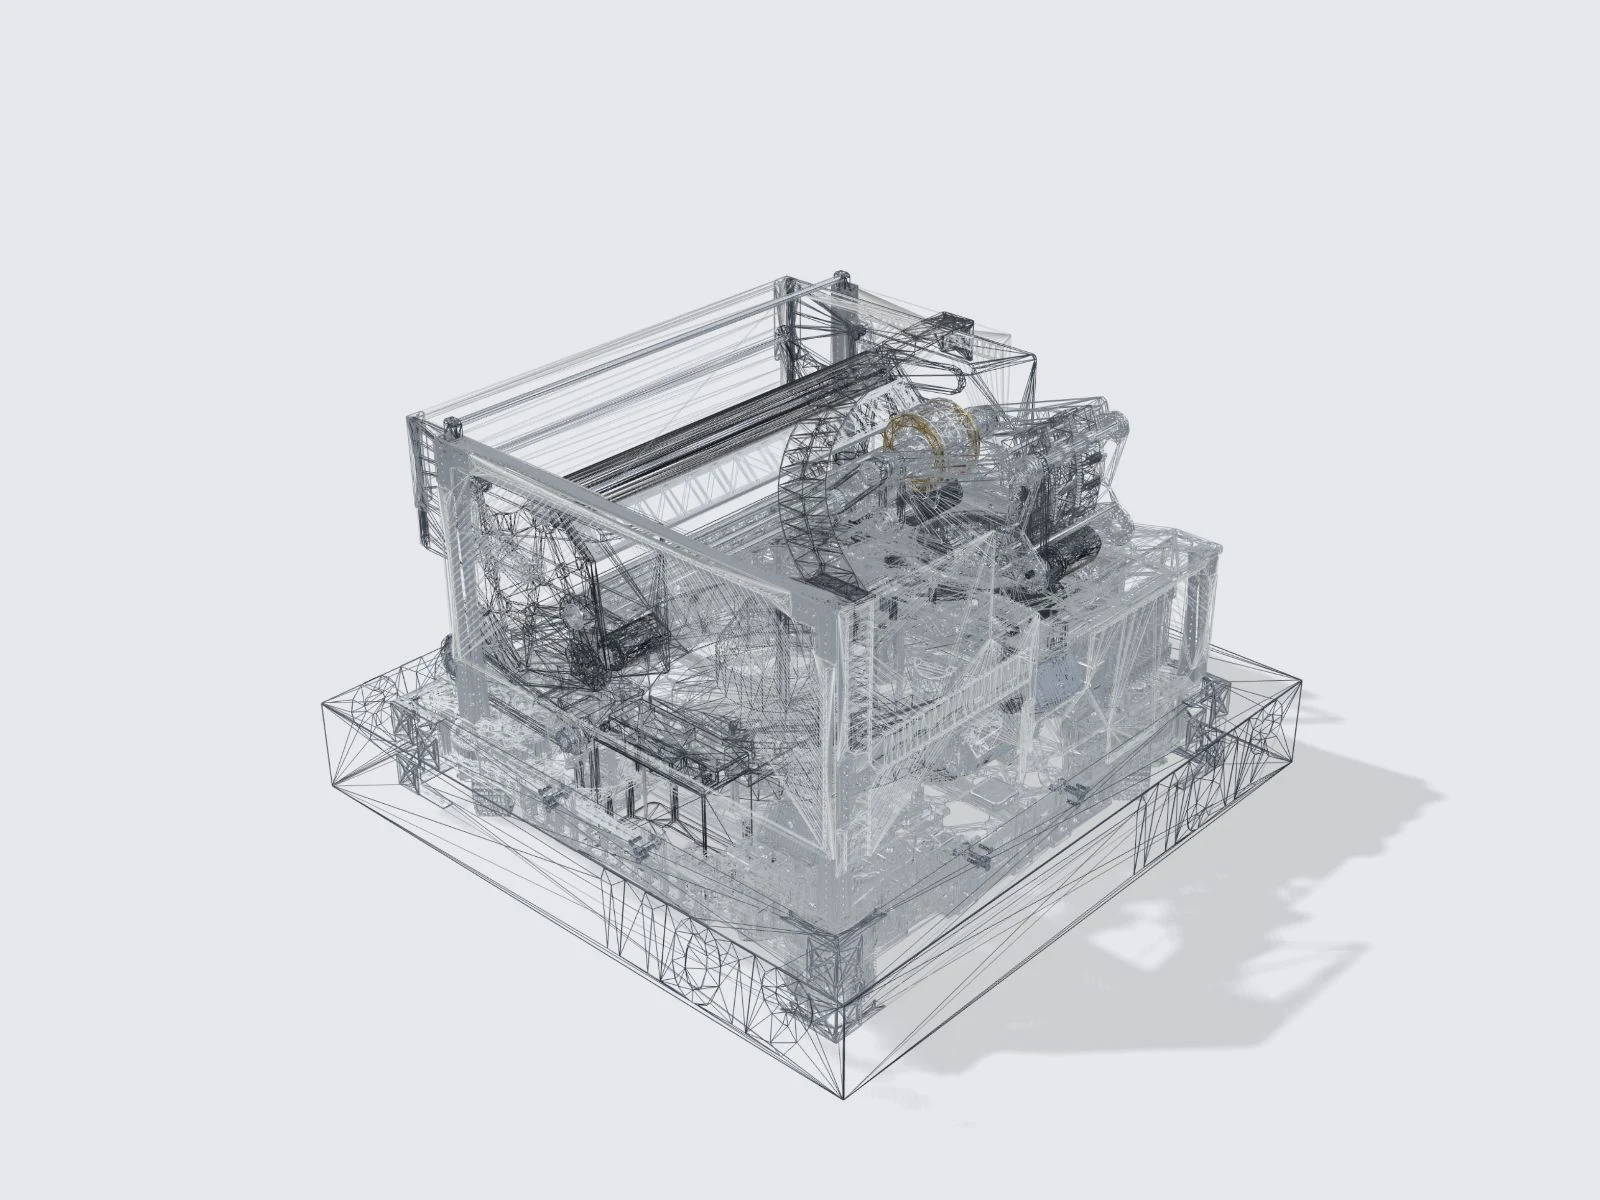
1600 × 1200
The tessellated geometry from the same model and camera as the studio view. Compare surface appearance with the underlying mesh.
September CAD-derived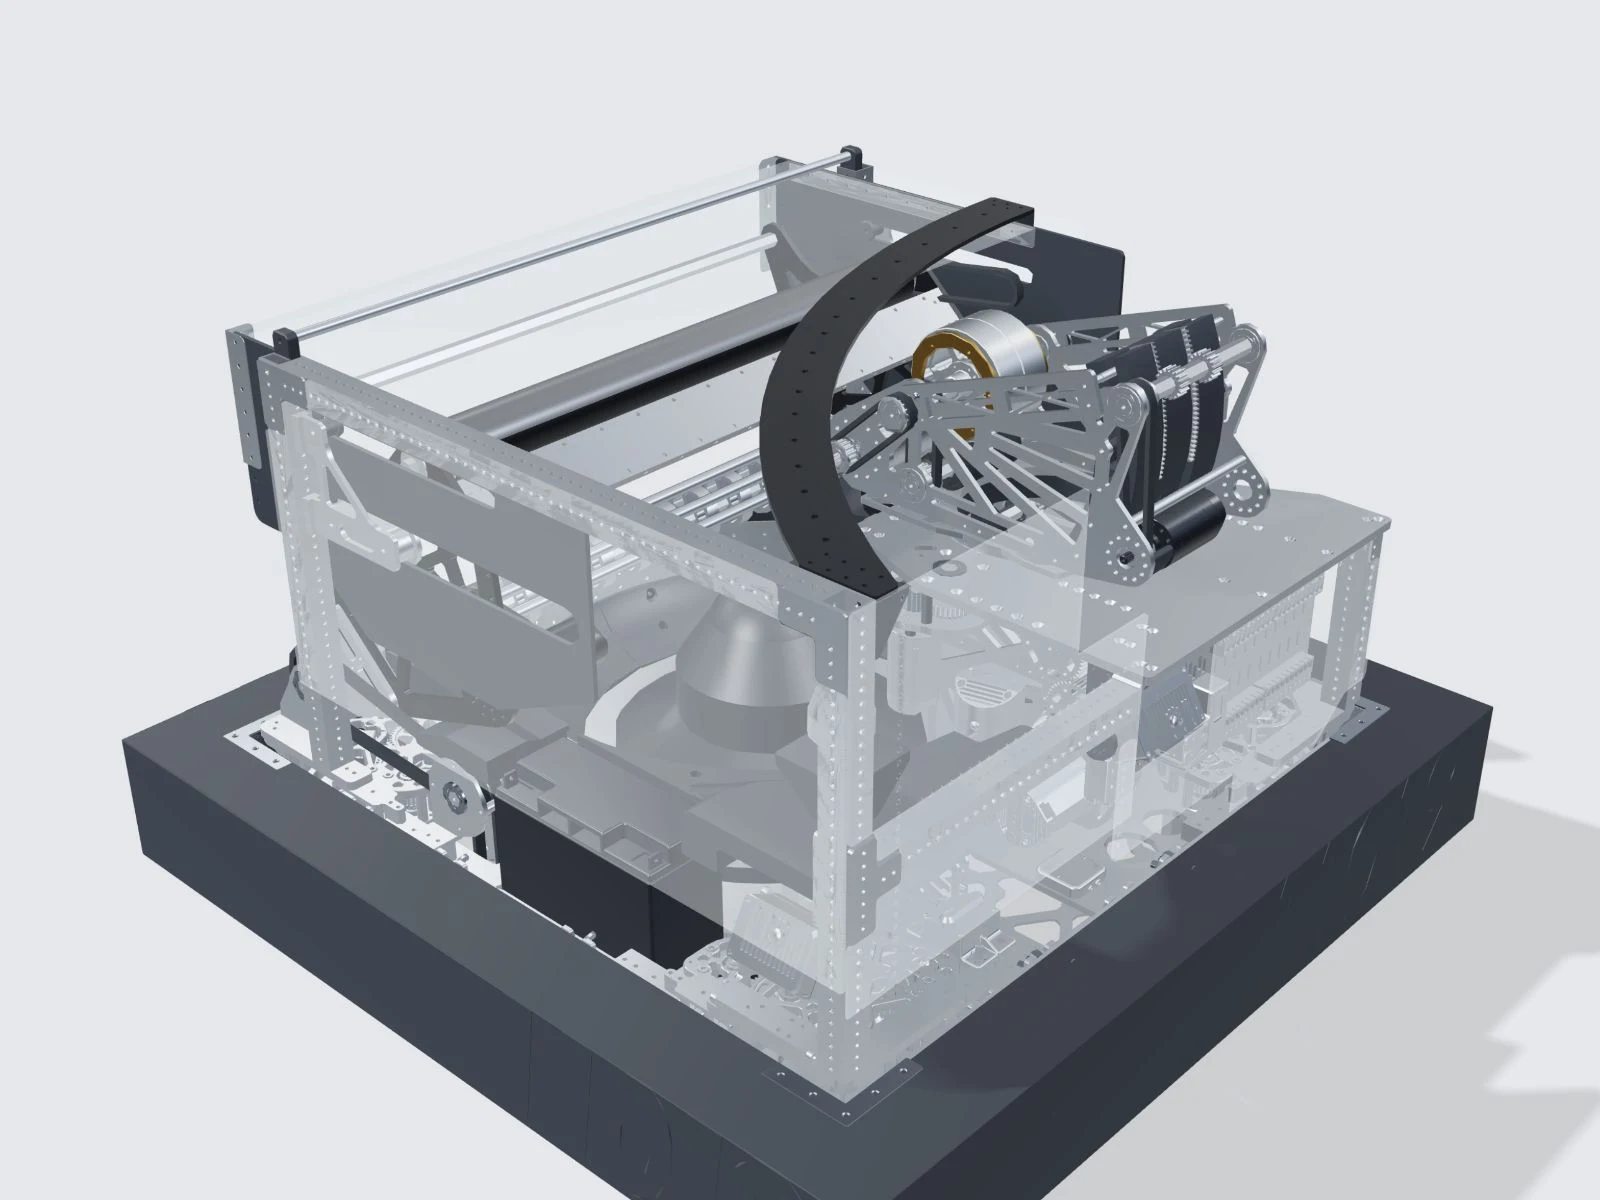
1600 × 1200
A closer view of the robot structure and mechanism interfaces. Pair it with the architecture chapter for a guided reading of the assembly.
September CAD-derived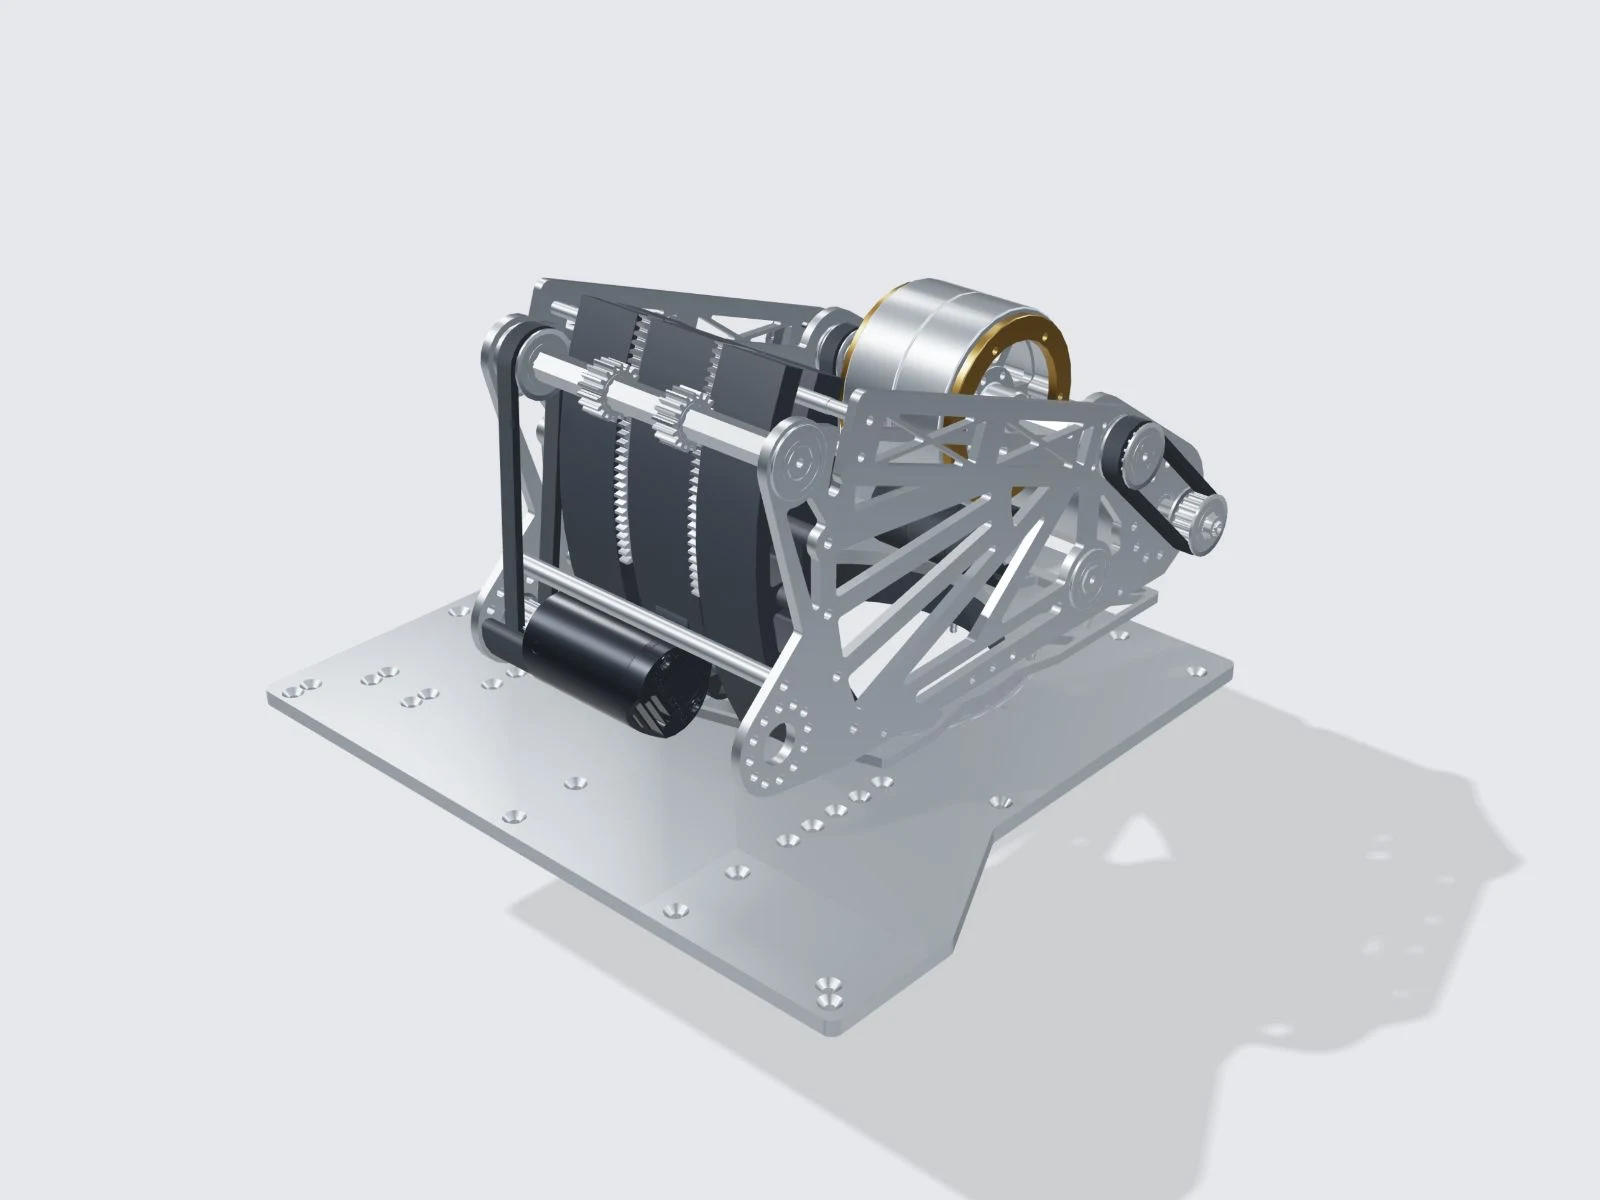
Public example · MIT
A WPILib Java example for coordinating a dual-motor arm and elevator. Explore mechanism IO, travel limits, interlocks, telemetry, tests and engineering logs. Hardware-specific calibration is required.
Public repository
Starter framework · MIT
A minimal WPILib project with a clean elevator subsystem scaffold and an engineering log. It is a starting framework, not a functioning elevator controller.
Public repository
Original-language documentation
Documentation for an FRC-focused printer-management platform: monitoring, print queues, filament inventory and robot parts. This repository contains documentation, not the application source.
Public documentationThe March manual and September CAD describe different robot revisions. Specifications on this site are from the March manual. Rendered colours and finishes are illustrative. The GLB models do not include validated movement limits.
Public software examples have their own instructions and limitations. Review configuration, calibration and safety requirements before adapting code to physical hardware.