A drive system in which each wheel module controls its steering angle and drive speed independently.
XPLORE 11019 / LEARNRobot
Robot
engineering.
Learn how the robot collects, drives and shoots. Each guide connects a clear explanation with models, demonstrations and technical references.
THREE WAYS INTO THE ENGINEERING
Choose a topic.
Use the robot as a practical example. Each path links short explanations to the technical manual, CAD and interactive demonstrations.
START HERE
How the mechanisms work
Begin with the complete machine, then trace collection, feeding and launch. No CAD experience required.
- 01↗
Robot systems
How the drivetrain, intake, hopper, feeder and shooter work together.
- 02↗
Intake and feeding
Rollers collect FUEL from the floor. The hopper stores it, and the feeder delivers it to the shooter.
- 03↗
Turret and shooter
The turret controls aiming direction, the hood controls launch angle, and the flywheels control ball speed.
TRY A SIMPLE MODELWhat happens
What happens
during 120 ms?
A delayed observation describes an earlier moment. Change the speed and delay to see how far a robot travelling at constant speed would move before the observation arrives.
Read the full explanationmetres travelled
Distance = speed × delay. Constant-speed illustration; not measured pose error.
THE WORKING VOCABULARY
A few useful terms.
A rotating assembly that aims the shooter without requiring the chassis to turn.
The curved guide that sets the angle at which the ball leaves the shooter.
An estimate of movement built from wheel travel, steering angles and inertial measurements.
The robot’s position and heading, measured relative to a reference such as the field.
The delay between an observation or action and the time that information becomes available.
A planned or measured path that includes where an object is at each point in time.
A target value sent to a controller, such as flywheel speed, hood angle or turret heading.
Bill of materials: the list of parts and material information associated with an assembly.
A compact binary 3D format used here to make CAD-derived geometry available in the browser.
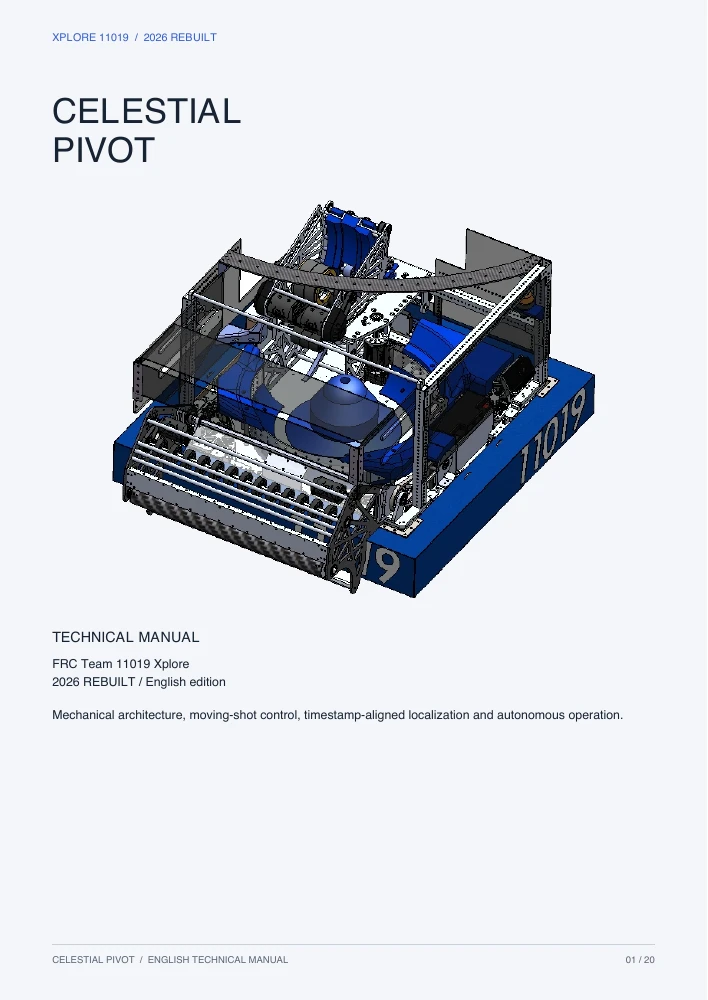
OPEN ENGINEERING / 20 PAGES2026 technical
2026 technical
manual.
The 20-page manual covers mechanical design, shot calculation, camera-based position tracking and autonomous control, with diagrams and specifications.
Read the technical binder ↗Browse documentation, software and media