Floor intake
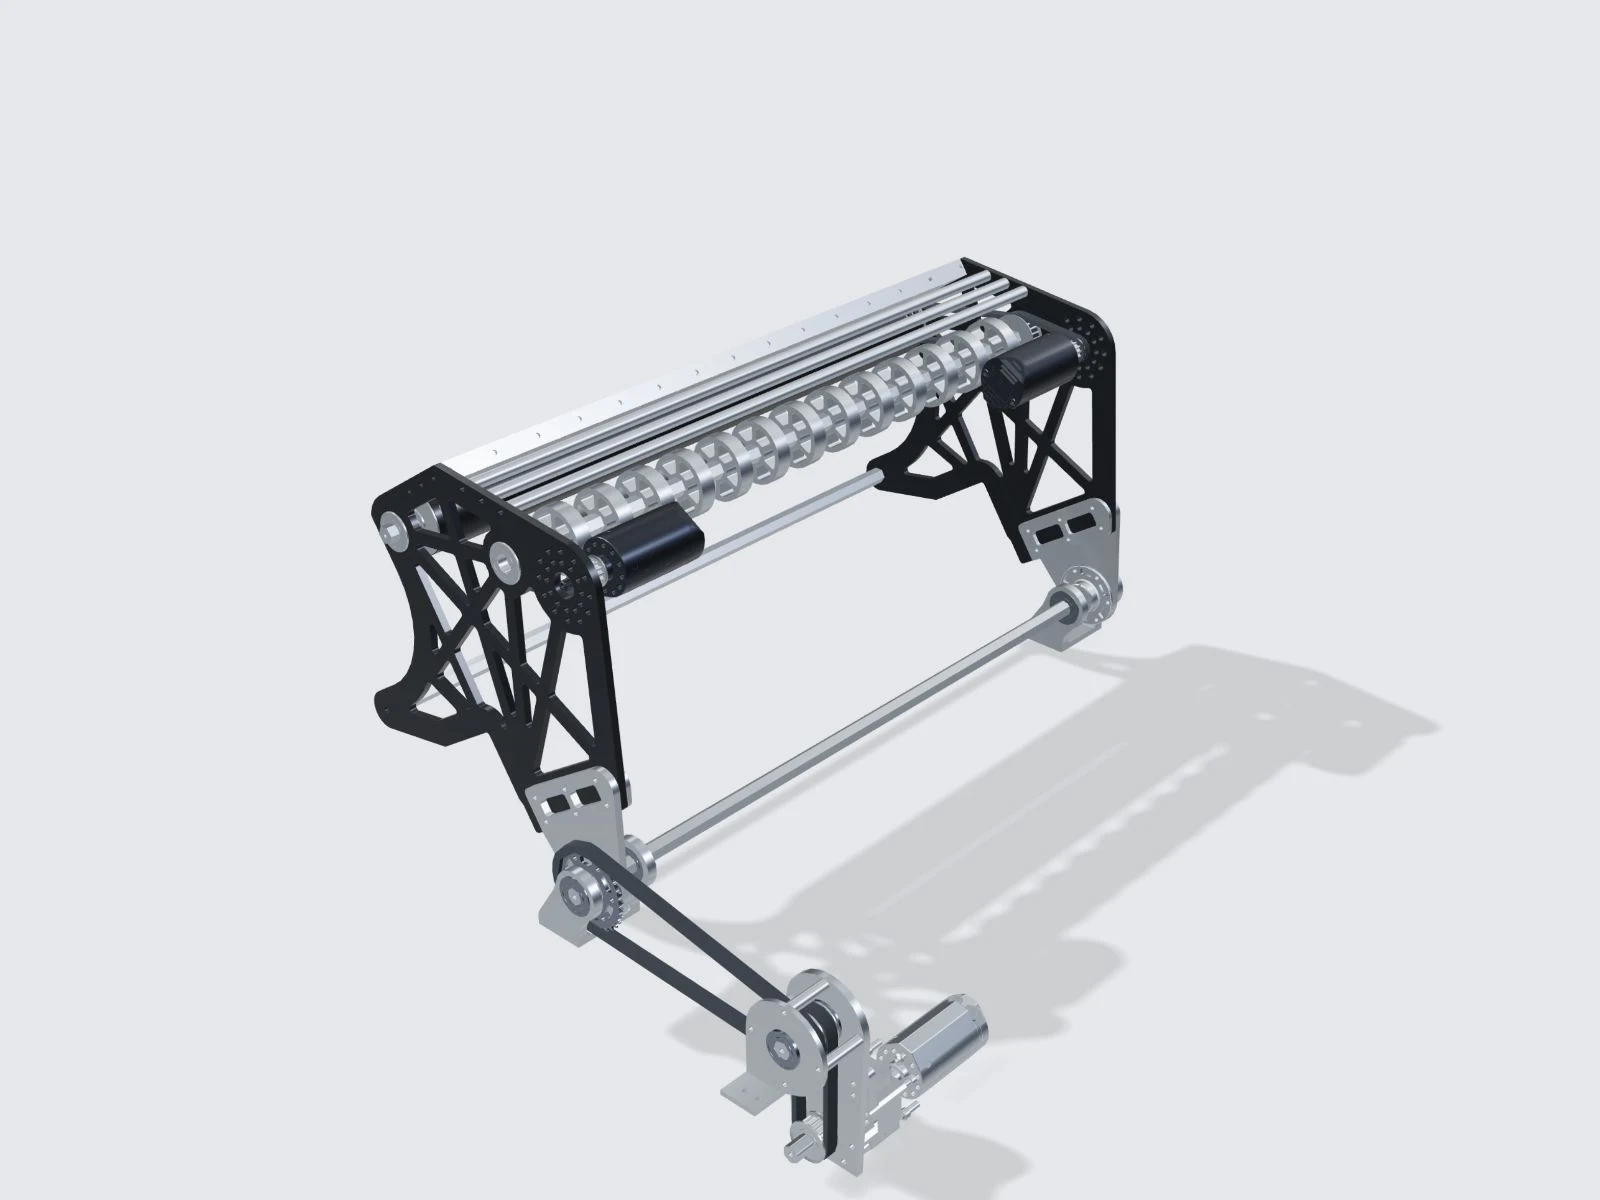
The March design uses two 35 mm carbon-tube rollers, driven by two Kraken X44 motors through 1:3 gearing. Positioned low at the front, the rollers draw FUEL from the floor toward the hopper entrance.
The intake’s position and roller motion determine how balls enter the robot. Its outlet must line up with the storage area so collected balls can continue through the machine.
Expandable storage
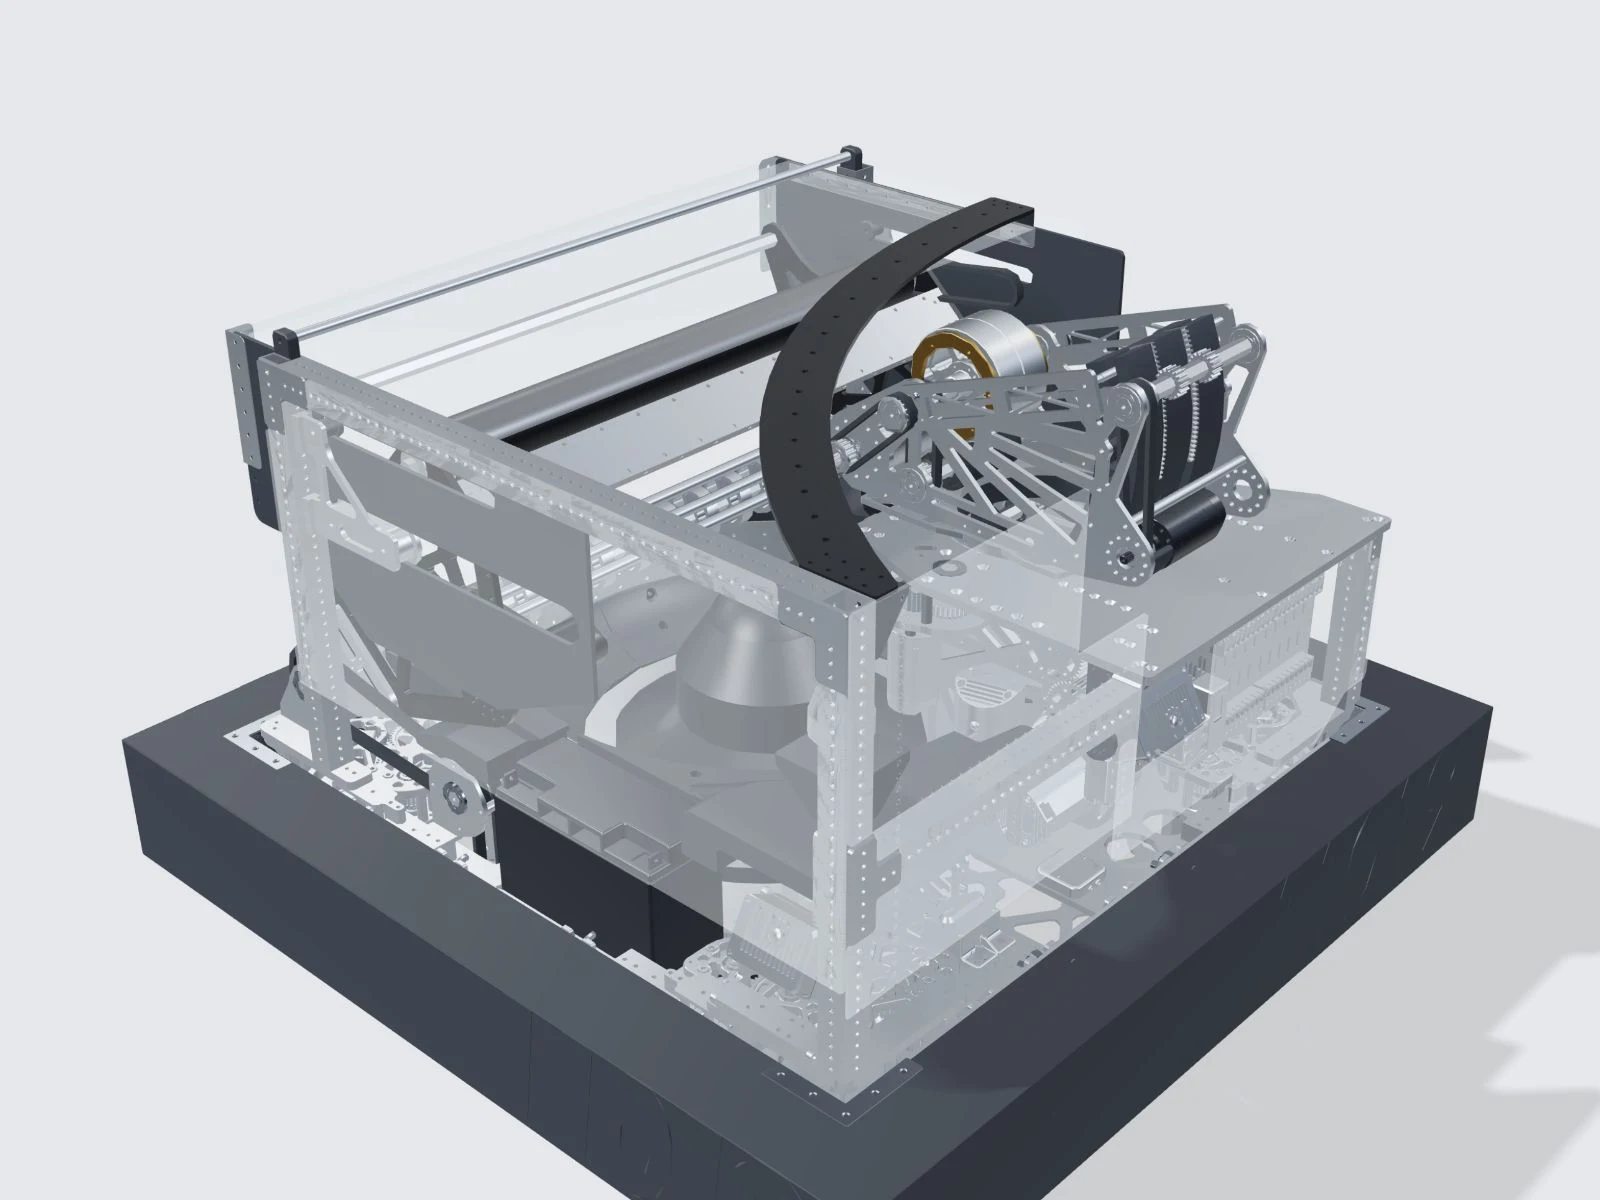
The sliding hopper extends by 260 mm. Polycarbonate inner walls provide a low-friction surface, while 3080 and 5050 supports attach the hopper to the chassis. Upper netting helps retain the balls.
The storage area must also feed reliably. Perimeter guides help direct balls away from structural corners and toward the transfer mechanism, where the feeder can reach them.
Feeding the shooter
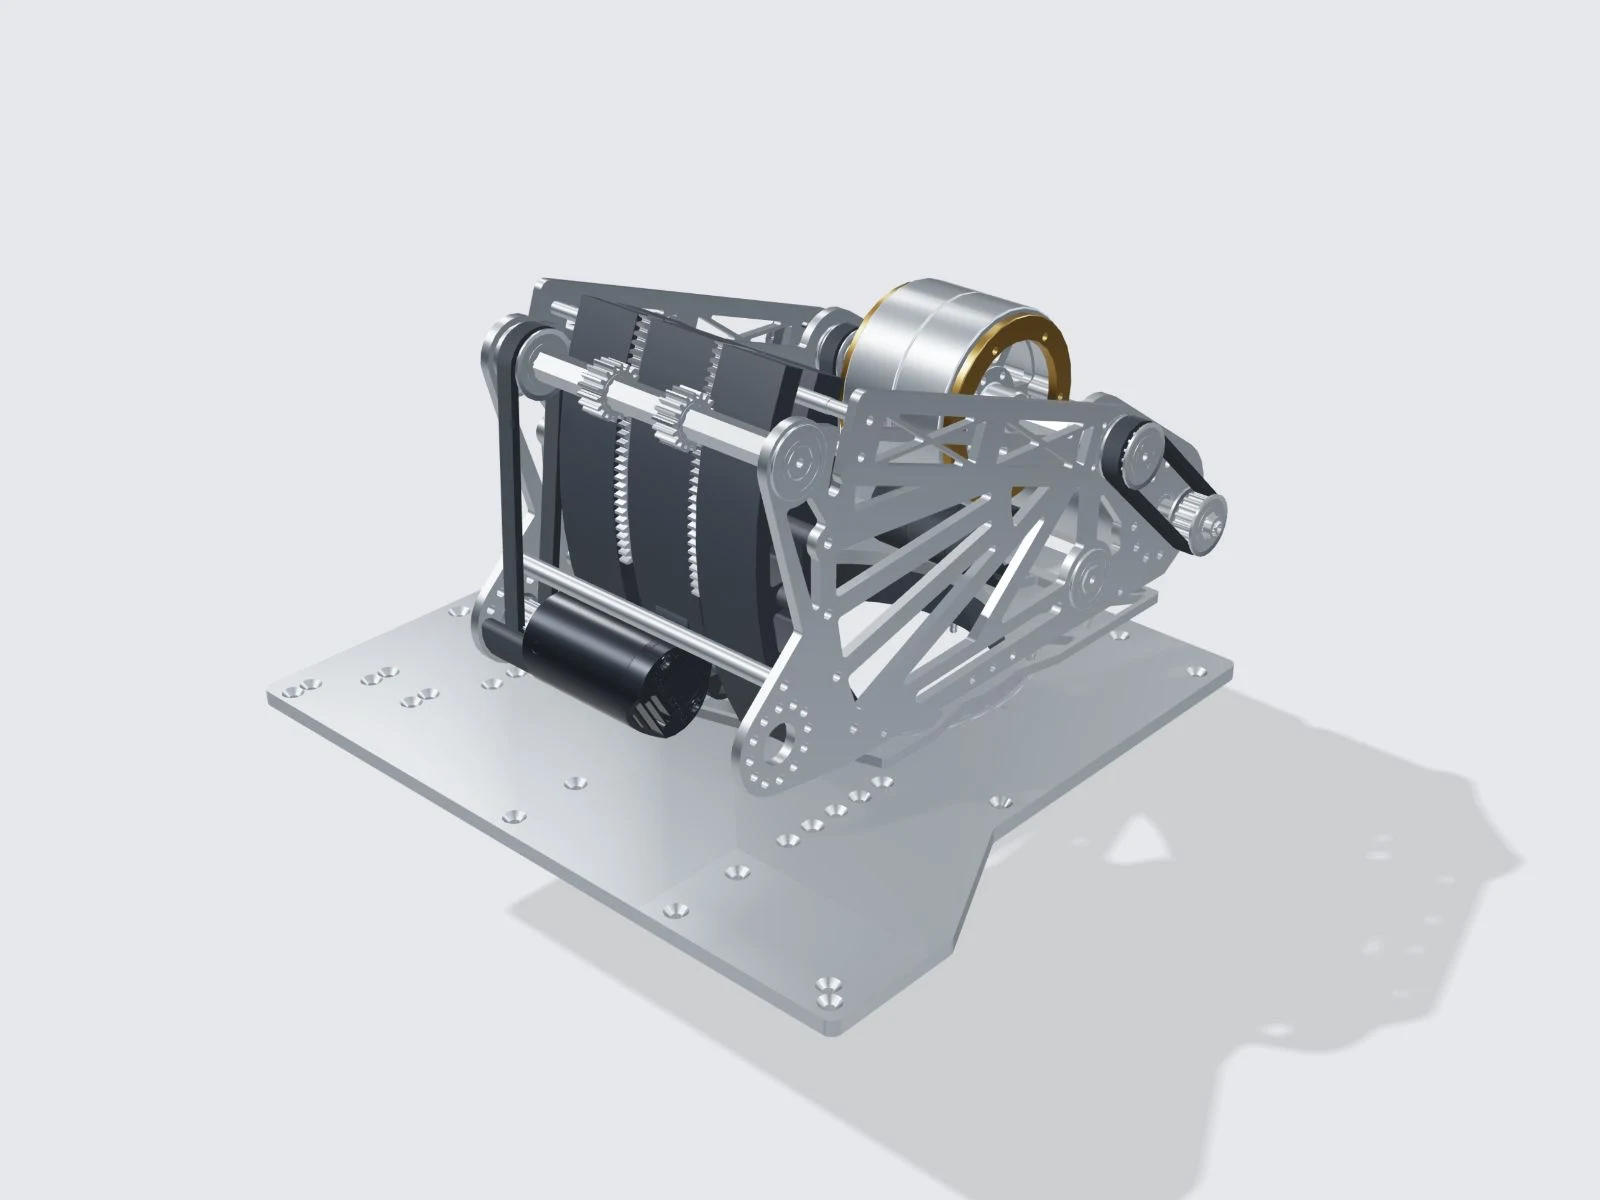
The indexer and rotator use two Kraken X60 motors, with 1:10 and 1:1.5 gearing. Printed ABS/PLA parts shape the contact surfaces, and aluminum reinforcement supports the assembly.
The September standalone intake differs from the intake in the complete robot export. Both models retain their original configuration. Compare them as separate revisions rather than interchangeable assemblies.