Match the image to its capture time
The robot can move between the moment a camera captures an image and the moment software receives it. Using the image as a measurement of the current position would apply the correction at the wrong time.
Instead, the system finds the position and heading recorded at capture time. It corrects that earlier estimate, then applies the wheel and gyro movement recorded since capture to update the current estimate.
Check each measurement
Two Limelight cameras provide independent samples. Each camera prefers MegaTag 2 and falls back to MegaTag 1 when MT2 is unavailable. A single frame is used only once.
The system adjusts measurement confidence based on tag image area, robot speed, turning rate and camera calibration. It rejects ambiguous measurements, implausible heights and positions outside the field. MT2 already uses gyro heading, so that heading is not reused as independent evidence.
Review the logs
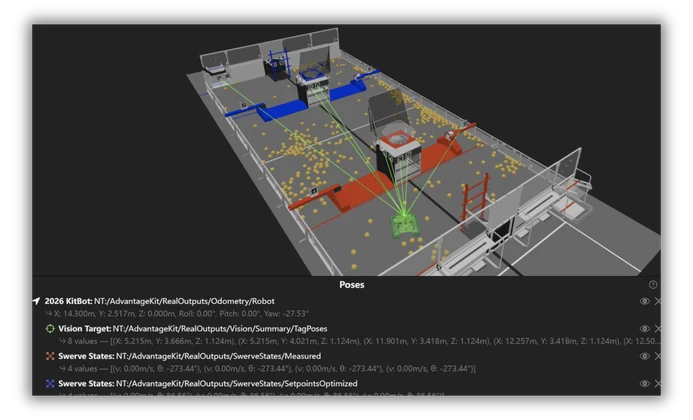
AdvantageKit records camera inputs, candidate position estimates and the reason each measurement was accepted or rejected. AdvantageScope can replay these decisions after a run.
The interactive panel shows how far a robot travels during a camera delay at constant speed. This distance illustrates the timing problem; it is not a measured position error.